← Back to projects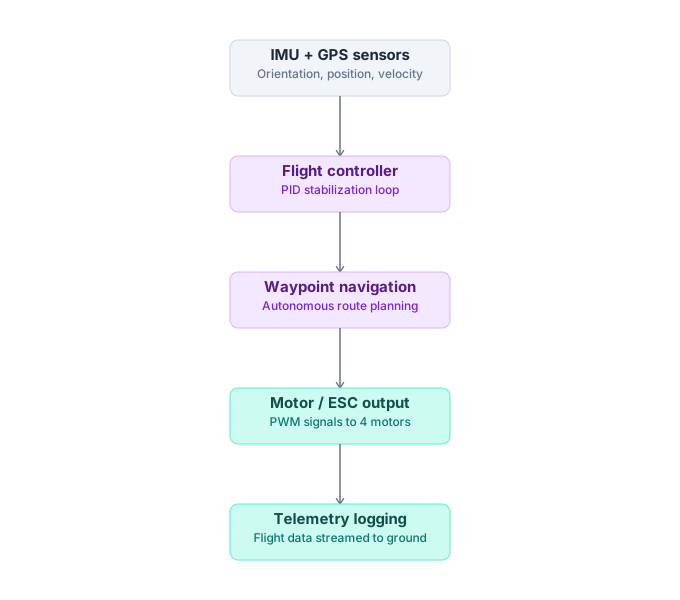
Case study
Autonomous Drone
Flight-controller-based drone with waypoint autonomy and telemetry logging.
Flight ControllersC/C++Networking ProtocolsPID Tuning
Waypoint accuracy
±1.5m (GPS-only)
Telemetry range
~800m
Failsafe response
<2s to RTH trigger
Problem
Needed reliable autonomous waypoint navigation on a budget flight controller stack, with a telemetry link resilient enough for beyond-line-of-sight status monitoring in an open field.
Stack
- ArduPilot/Betaflight-class FC
- MAVLink telemetry
- GPS + barometer + IMU fusion
- Ground station (Python)
Architecture
Outcome
Tuned PID gains and failsafe geofencing achieved stable autonomous waypoint runs with automatic return-to-home on link loss, validated over repeated field tests.